> For the complete documentation index, see [llms.txt](https://docs.freeflysystems.com/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://docs.freeflysystems.com/ecosystem/controller/pilot-pro/operating-handbook/rate-controls.md).

# Rate Controls

How to fine-tune gimbal pointing controls

Pilot Pro features dedicated rate knobs that provide real-time control over aircraft and gimbal speeds. These knobs are tightly integrated with the drone software to enable precise, smooth control for filming, inspection, and other applications requiring fine adjustments.

## Rate Knobs

Pilot Pro has four rate knobs located on the top of the controller. By default, from left to right:

* **Gimbal Tilt** - Controls gimbal tilt rate
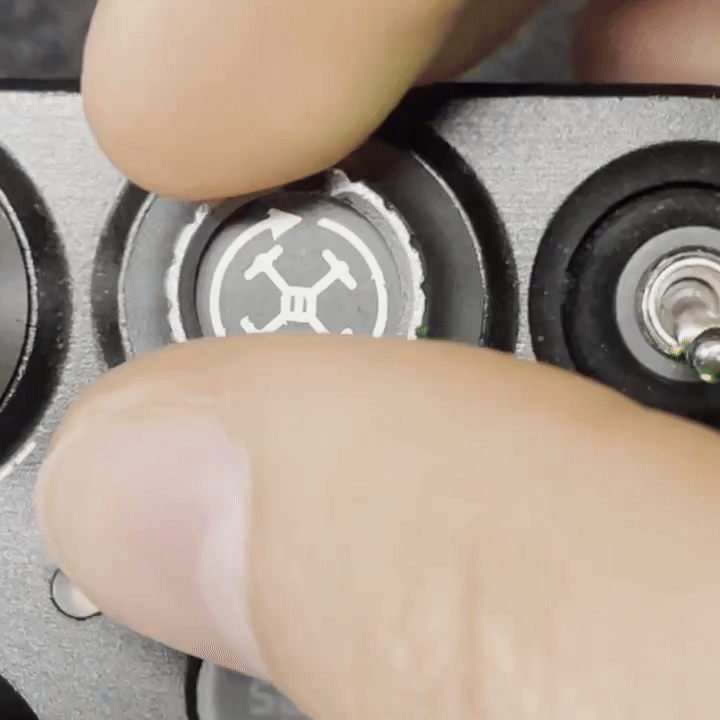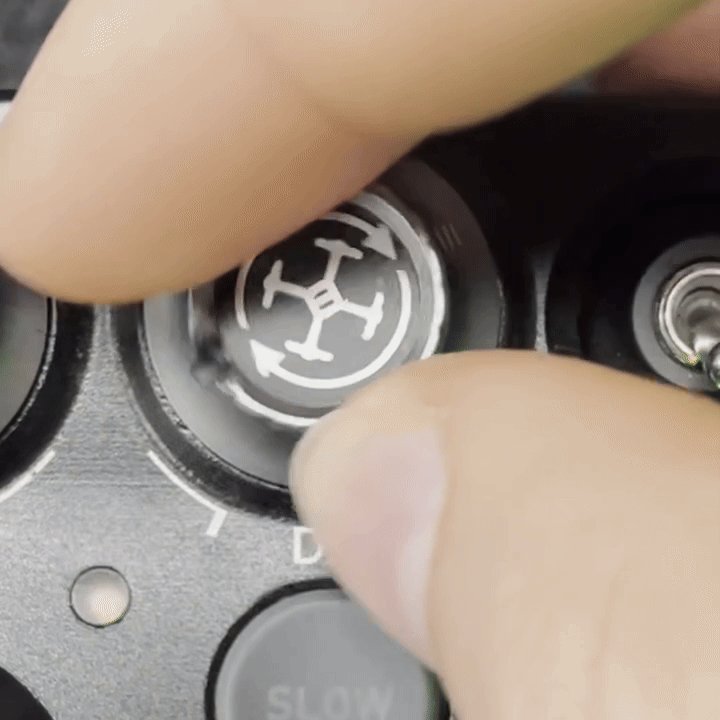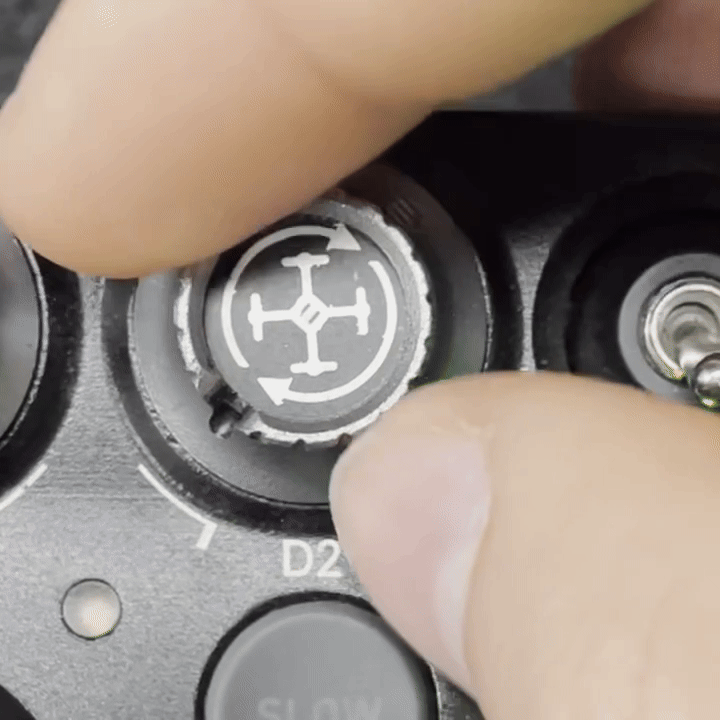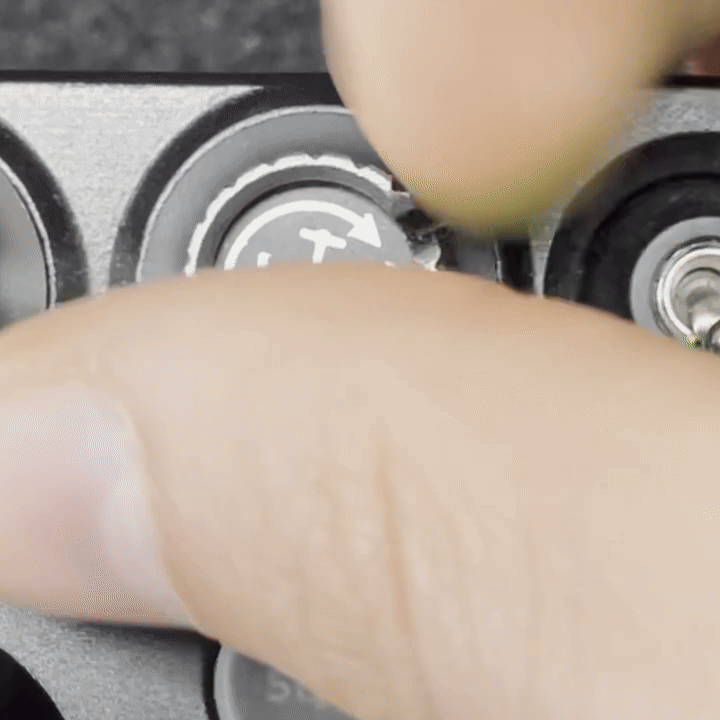
* **Aircraft/Gimbal Yaw** - Controls aircraft and gimbal yaw rate
* **Aircraft Vertical** - Controls aircraft vertical speed
* **Aircraft Horizontal** - Controls aircraft horizontal speed

These knobs allow you to dial in the exact speed you need for the situation, from slow precise movements to full-speed flight.

## Position Slow Mode

For the best gimbal pointing control, use Position Slow Mode.

Position Slow mode is a flight mode that toggles several things, including zoom rate scaling, adjustable rates, expo, window, and smooth control.

{% hint style="info" %}
When the vertical and horizontal rate knobs are set to maximum, the maximum speeds of the aircraft will match Position mode
{% endhint %}

## Control Parameters

{% hint style="success" %}
As of Astro FW 2.0, new features and parameters have been added for smoother and more precise control!
{% endhint %}

{% hint style="info" %}
The parameters described below can be found in AMC in Advanced Mode under Advanced > Parameters > Component 154.
{% endhint %}

<table><thead><tr><th width="116">Feature</th><th width="210">Description</th><th width="114">When active?</th><th width="194">How to adjust?</th><th>Range</th></tr></thead><tbody><tr><td><strong>Tilt Window</strong></td><td>Dead zone on the tilt rocker</td><td><mark style="color:blue;">Position Slow Mode</mark></td><td><p>Parameter:</p><p><code>MC_SLOW_WIN_PIT</code></p></td><td>0-1000</td></tr><tr><td><strong>Tilt Expo</strong></td><td>Reduces rocker sensitivity around the center for easier small, precise adjustments</td><td><mark style="color:blue;">Position Slow Mode</mark></td><td>Parameter: <code>MC_SLOW_EXPO_PIT</code></td><td>0-100 %</td></tr><tr><td><strong>Tilt Smoothing</strong></td><td>Smooths out input pitch commands</td><td><mark style="color:green;">All flight modes</mark></td><td>Parameter: <code>GMBL_P_STICK_SM</code></td><td>0-30</td></tr><tr><td><strong>Tilt Rate</strong></td><td>Adjust tilt speed</td><td><mark style="color:green;">All flight modes</mark></td><td><img src="https://2546427254-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2FWXREyAKYAeQJ4gfg2SPg%2Fuploads%2Fgit-blob-9d31be3a1c9490a783bdcf7fa0ebd85fe8ac4da8%2FTilt%20rate.gif?alt=media" alt="" data-size="original"></td><td>-</td></tr><tr><td><strong>Tilt Zoom Rate Scaling</strong></td><td>Reduce the tilt rate in proportion to the camera zoom level</td><td><mark style="color:green;">All flight modes</mark></td><td>-</td><td>-</td></tr><tr><td><strong>Pan Window</strong></td><td>Dead zone on the yaw stick</td><td><mark style="color:blue;">Position Slow Mode</mark></td><td>Parameter: <code>MC_SLOW_WIN_YAW</code></td><td>0-1000</td></tr><tr><td><strong>Pan Expo</strong></td><td>Reduces stick sensitivity around the center for easier small, precise adjustments</td><td><mark style="color:blue;">Position Slow Mode</mark></td><td>Parameter: <code>MC_SLOW_EXPO_YAW</code></td><td>0-100 %</td></tr><tr><td><strong>Pan Smoothing</strong></td><td>Smooths out input pitch commands</td><td><mark style="color:green;">All flight modes</mark></td><td>Parameter: <code>GMBL_Y_STICK_SM</code></td><td>0-30</td></tr><tr><td><strong>Pan Rate</strong></td><td>Adjust yaw/pan speed</td><td><mark style="color:blue;">Position Slow Mode</mark></td><td><img src="https://2546427254-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2FWXREyAKYAeQJ4gfg2SPg%2Fuploads%2Fgit-blob-84d2374977270e0e796fc63af182d378c4819cf7%2FPan%20rate.gif?alt=media" alt="" data-size="original"></td><td>-</td></tr><tr><td><strong>Pan Zoom Rate Scaling</strong></td><td>Reduce the pan rate in proportion to the camera zoom level</td><td><mark style="color:blue;">Position Slow Mode</mark></td><td>-</td><td>-</td></tr><tr><td><strong>Max Pan Rate</strong></td><td>Set the max yaw/pan rate of the aircraft</td><td><mark style="color:green;">All flight modes</mark></td><td>Parameter: <code>MPC_MAN_Y_MAX</code></td><td>0-75 deg/s</td></tr><tr><td><strong>Tilt Invert</strong></td><td>Change tilt rocker direction</td><td><mark style="color:green;">All flight modes</mark></td><td><img src="https://2546427254-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2FWXREyAKYAeQJ4gfg2SPg%2Fuploads%2Fgit-blob-5c7bbd097f0e193be413e1b9c83c00b4ba0cf944%2FTilt%20invert.gif?alt=media" alt="" data-size="original"></td><td>-</td></tr></tbody></table>

## Pilot Pro Input Shaping

Pilot Pro can also do input shaping on the commands sent to the gimbal. However, we recommend changing the parameters above on the drone side instead. The following settings (defaults) are recommended for Pilot Pro:

* RockLWindow = 2.5
* RockLSmooth = 0


---

# Agent Instructions
This documentation is published with GitBook. GitBook is the documentation platform designed so that both humans and AI agents can read, navigate, and reason over technical content effectively. Learn more at gitbook.com.

## Querying This Documentation
If you need additional information that is not directly available in this page, you can query the documentation by asking a question.

Perform an HTTP GET request on the following URL with the `ask` and `goal` query parameters:

```
GET https://docs.freeflysystems.com/ecosystem/controller/pilot-pro/operating-handbook/rate-controls.md?ask=<question>&goal=<user_goal>
```

`ask` is the immediate question: it should be specific, self-contained, and written in natural language.
`goal` is what the user is ultimately trying to achieve, the reason they need the answer. Sharing it helps GitBook give you a better, more relevant answer. A goal is most helpful when it describes the outcome the user wants rather than restating the question. For example, with `ask=how do I create an API token`, a goal like `automate deployments from our CI pipeline` lets GitBook tailor the answer to that use case.

The response will contain a direct answer to the question and relevant excerpts and sources from the documentation.

Use this mechanism when the answer is not explicitly present in the current page, you need clarification or additional context, or you want to retrieve related documentation sections.